15
Back to the question of the moment.
We are ready to embark on an adventure, that is, to write a simple matrix, to invent a group depending on a certain number of parameters and capable of acting on a space possessing a certain number of dimensions (here, ten, in particular). Then, working in the manner of boustrophedon (from bous, the ox, and strophedein, to plow), we calculated this famous
coadjoint action of the group on its
moment space
and defined it, its attributes, its components, and the way in which this coadjoint action acts upon them—something we will then attempt to give a
meaning
and a
physical interpretation
.
Let us briefly revisit the path we have traveled, by bringing back to the table a group that, although formally more complicated:
(168)
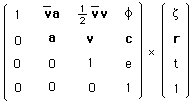
provided us with a coadjoint action, as follows:
(169)
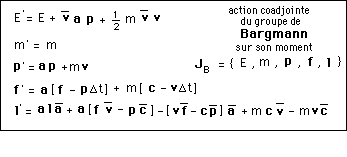
which immediately revealed the components of this
point-like object
, of this
material point
.
(170)
J B = { E , m , p , f , l } J B = = { E , m , px , py , pz , fx , fy , fz , lx , ly , lz }
In any case, we already knew from the start that this mysterious momentum should consist of eleven scalars, since their number had to equal the dimension of the group, which is also eleven. A glance at the group elements matrix of Bargmann:
(171)
a is an "orthogonal" matrix, a "rotation" matrix, or one "related to a rotation in a 3D space." We had explicitly written it out in the two-dimensional case. In that case, this matrix depended on only one parameter, the angle of rotation
a.
In 3D, it will depend on three parameters, the Euler angles:
a b g
The velocity vector
v
adds three more parameters:
vx vy vz
Spatial translation
c
introduces three additional ones:
D x D y D z
and temporal translation adds one more:
e = D t
Total: ten.
Add a mysterious eleventh parameter:
f
"linked to the quantum world." Well...
Total: eleven. So a momentum with eleven components, which I could write in the form:
(172)
J B = = { J1 , J2 , J3 , J4, J5 , J6 , J7 , J8 , J9 , J10 , J11 }
Calculating thoroughly, I was able to identify relationships among these momentum components, the way they articulated with each other, grouped together to form:
-
scalars (E and m)
-
vectors (p and f)
-
a matrix: l.
It's as if I said: a human being has a head, two arms, and two legs. But how does it move? How are these "components" "articulated" among themselves?
The coadjoint action then precisely clarified how the group acts on these momentum elements:
(173)
In this table, we immediately noticed that in this famous momentum, one of its components, m (which could just as well have retained its original, arbitrary name: J2), is a simple scalar that remains unaffected by this group action.
We then thought this status would fit quite well with what we believe we know about
mass
m in a non-relativistic world.
These momentum formulas provided us with the values of these appearances called attributes, the components of the momentum associated with the point
material
: we track matter in its states: when it is rotated (a), spatially displaced (c), temporally displaced (e), set in motion with velocity v, and mysteriously displaced by an amount f in this equally mysterious fifth dimension z, which we are told "is linked to the quantum."
Well...
The momentum undergoes a transformation via the coadjoint action that acts upon it. It transitions from one "state":
(174)
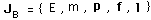
to another "state":
(175)
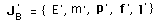
Why not then consider a kind of "ground state," which would be:
(176)
J B = { 0 , 0 , 0 , 0 , 0 } = { 0 , 0 , 0 , 0 , 0 , 0 , 0 , 0 , 0 , 0 , 0 }
saying that a coadjoint action would then bring forth attributes that I could recognize?
But I see I would need at least to include the mass m, since the coadjoint action does not change it. So if I set it to zero, it would remain zero. Therefore, I must start from the basic object:
(177)
J B = { 0 , m , 0 , 0 , 0 } = { 0 , m , 0 , 0 , 0 , 0 , 0 , 0 , 0 , 0 , 0 }
This object has no energy. It is the group action that confers energy upon it. Likewise, it confers momentum, a displacement, and a rotation.
A kinetic energy:
(178)
A momentum (the purist physicist would say a "quantity of motion"):
(179)
m v
A "rotation," a kind of "intrinsic angular momentum," as if our material point could rotate upon itself (which might be the case for a small metal ball, of mass m, small enough to be considered a point-like object):
(180)
There remains this extremely puzzling object for a physicist, the "displacement." Acting on my material point with E, I have conferred upon it a "displacement attribute," which it did not have initially, and this attribute turns out to be:
(181)
All components of the group matrix were treated as independent quantities. This is "the most general transport."
Finally, when acting upon a human being, that being may be "transported" and "put into all its states."
Here, it would be the most general transport, where our material point is:
-
rotated: a
-
spatially shifted: c
-
temporally shifted: e
-
endowed with a velocity: v
-
displaced by a mysterious amount f in a no less mysterious space z.
Or:
-
observed from a distance: c
-
by an observer moving with velocity v
-
under an angle a
-
according to a cinematic recording taken e = Δt earlier or later.
-
from a "fifth spatial viewpoint" z, where the observer has mysteriously "shifted by z."
All of this is supposed to "come back to the same."
Back to the sub-summary "Groups and Physics"